Selected
work
A cross-discipline body of work spanning simulation, games, design, and tooling.
Simulation — Projects
ROBOS
At VirtaMed I helped build RoboS — the most advanced robotic surgery simulator on the market, delivering hyper-realistic training for da Vinci and next-generation robotic platforms.
My work spanned the full simulation stack: soft-body tissue deformation, rigid body-to-rigid body collisions using NVIDIA PhysX, and articulated robot body kinematics. The system had to faithfully reproduce the unique force feel and motion constraints of teleoperated surgical robots at real-time frame rates.
Watch trailerSimulation — Projects
LAPAROS
As a key contributor to the development of LaparoS at VirtaMed, I helped build the most advanced laparoscopic surgery simulators on the market.
My work focused on real-time simulation, complex instrument interactions, tissue deformation, grasping mechanics, and different collision systems. I also created and optimized anatomical models and surgical instruments, working closely with surgeons to translate real procedures into effective training experiences.
Watch trailerRoboS — Highlights
Soft Body Collisions
Custom multi-layer collision detection handling complex instrument–tissue interactions at real-time frame rates.
Fluid Simulation
Real-time fluid dynamics integrated into the surgical simulation for realistic bleeding, irrigation, and fluid pooling behaviour.
Soft-Body Grasping
Physically accurate soft-body grasping mechanics with constraint-based deformation responding to instrument grip forces.
Soft-Body Cutting
Real-time mesh cutting with topological changes, supporting scissors and blade instruments with accurate tissue separation.
Soft-Body Tearing
Dynamic tearing simulation with progressive mesh fracture, enabling realistic tissue rupture and separation under applied forces.
Soft-Body Clipping
Clip-based tissue manipulation allowing surgeons to apply and manage surgical clips with accurate deformation and hold mechanics.
Rigid Body Collision & Grasping
Combined rigid body collision and grasping system handling simultaneous instrument–object interactions with accurate contact resolution.
Articulated Bodies
Multi-segment articulated body simulation with joint constraints, enabling realistic instrument kinematics and anatomical articulation.
Cloth Simulation
Position-based cloth simulation for surgical drapes and flexible anatomical membranes with accurate folding and collision response.
Needle Handling
Precise needle interaction and suturing mechanics with thread simulation, enabling realistic laparoscopic suturing training scenarios.
Rods Simulation
Cosserat rod simulation for flexible instruments and suture threads, providing stable and accurate bending, twisting, and stretching behaviour.
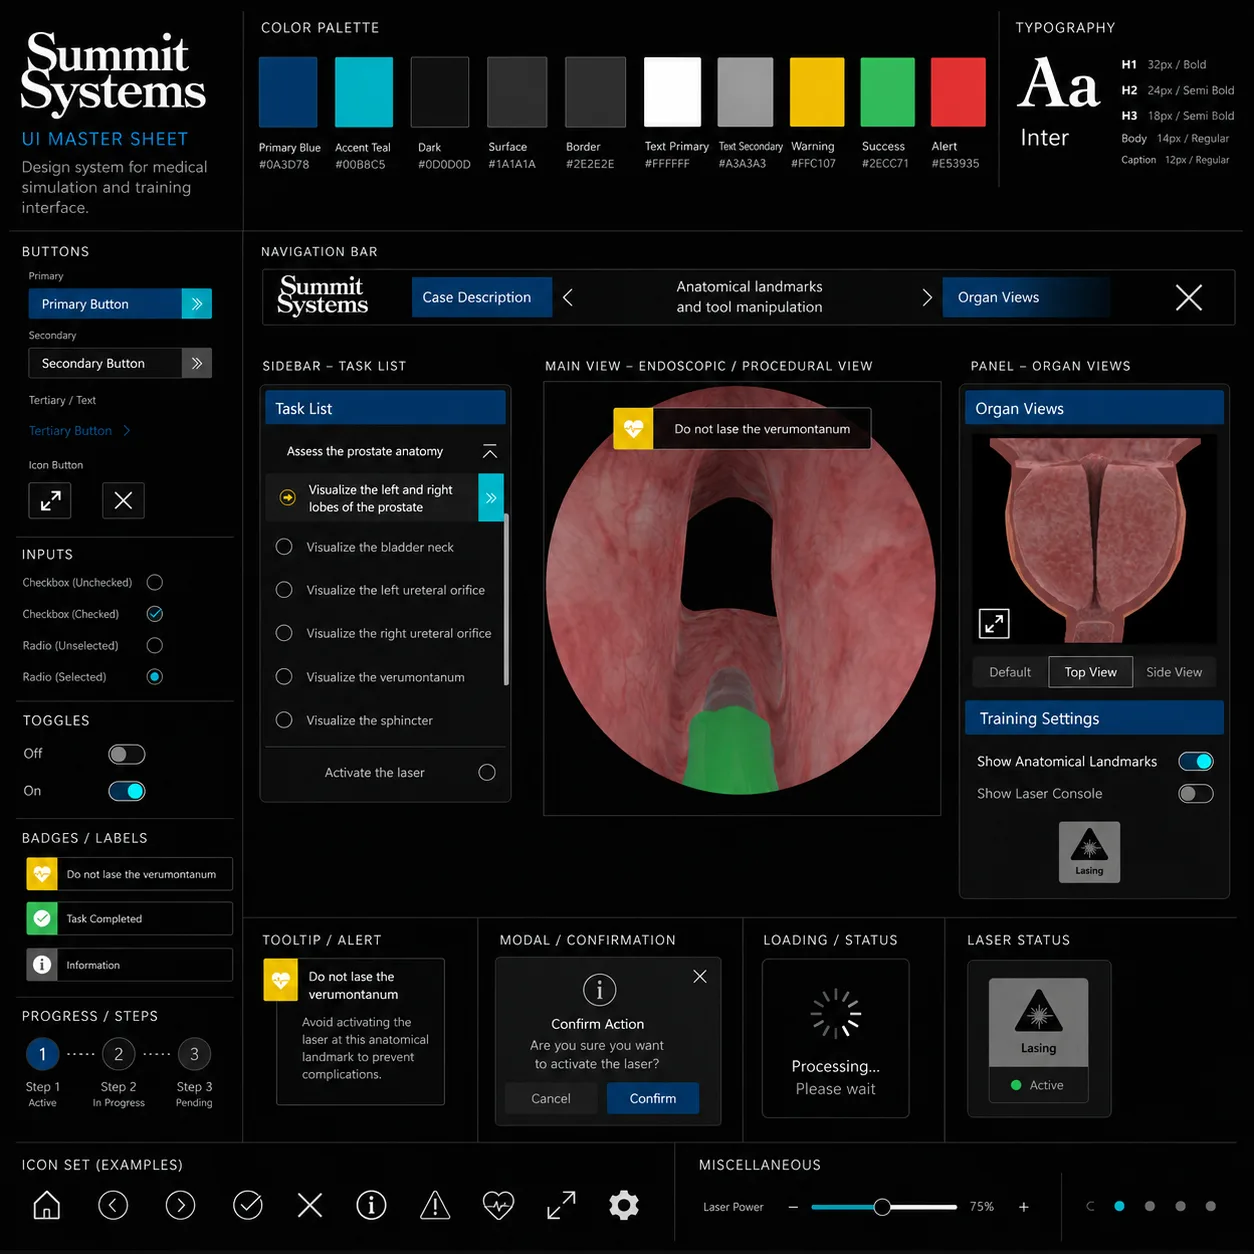
UI
Simulation interface design — instrument controls, feedback panels, and real-time parameter displays built for clarity under the demands of surgical training workflows.